01
REAL-TIME PERCEPTION
Real-Time Analysis
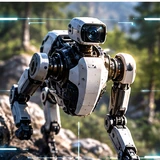
We research low-latency image processing and efficient visual structure extraction for real-time edge perception.
 VIMBERIA
VISION FOR
AUTONOMOUS MACHINES
Integrated perception
across complex environments.
Moving objects, behavior
and intent in real time.
Optimized for embedded
and edge systems.
Built for low light, weather
and real-world conditions.
REAL-WORLD APPLICATIONS
Vimberia explores embedded vision AI and real-time object recognition for drones, robotics, industrial inspection, autonomous vehicles and maritime navigation — with low-power deployment and robustness to difficult sensor conditions in mind.
Explore Use Cases Aerial SystemsSmarter flight. Safer skies.
 Ground RoboticsPerception for any terrain.
 IndustrialSmarter inspection and automation.
 Autonomous VehiclesConfidence in motion.
 MaritimeAwareness beyond the horizon.
Explore industry-specific requirements, engineering trade-offs and proposed integration pathways. View all five solution areas →
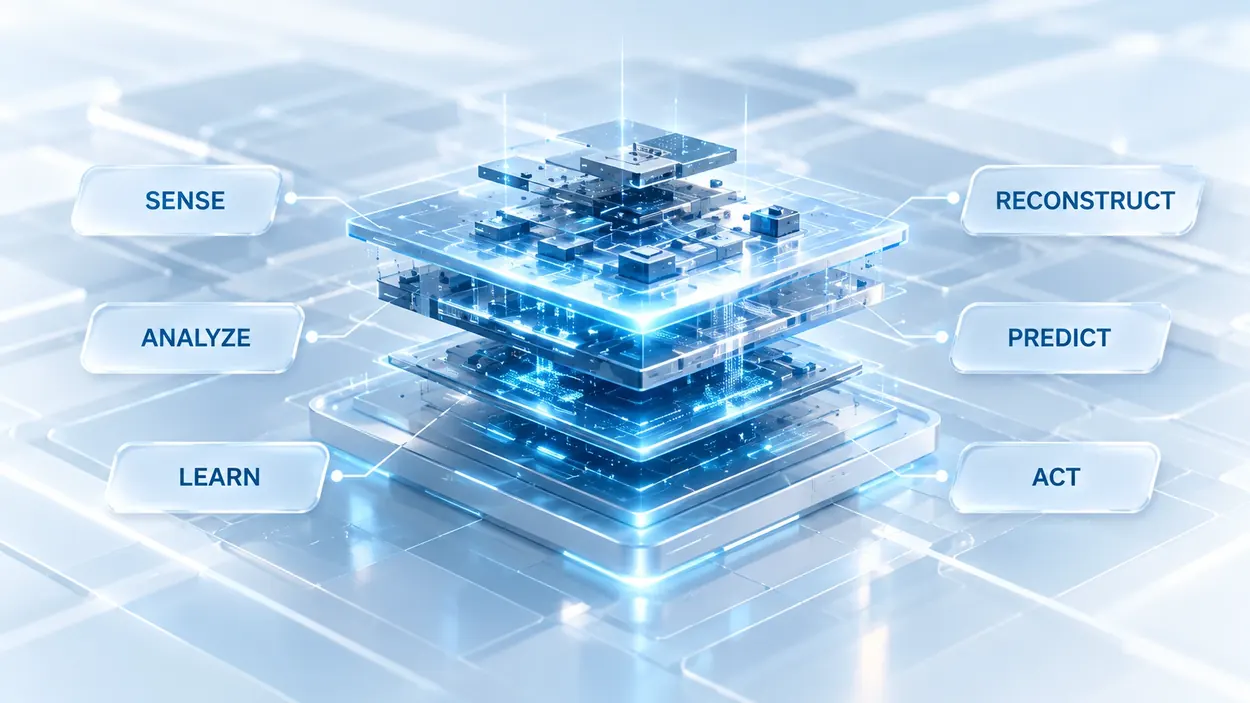
Real-time perception, learning and spatial intelligence — engineered with efficiency and deployment in mind.
REAL-TIME PERCEPTION
We research low-latency image processing and efficient visual structure extraction for real-time edge perception.
LEARNING
Vimberia investigates learning from field observations, aiming to reduce dependence on large manually labeled training datasets.
MODEL INSIGHT
Our research explores inspectable visual representations and reproducible evaluation of recognition behavior.
EFFICIENCY
The engineering goal is resource-efficient perception that can operate locally where cloud connectivity and power are constrained.
DATA EFFICIENCY
Compact visual representations are being investigated to help limit image transmission requirements.
ADAPTABILITY
We study how sensor noise, changing illumination and different camera formats affect perception and integration.
SPATIAL UNDERSTANDING
Research aims include geometric scene understanding, visual correspondences and persistent spatial mapping.
EDGE COMPUTING
We target constrained embedded computers in drones, robots and mobile platforms, subject to hardware-specific testing.
Explore how Vimberia’s research could fit your platform and real-world constraints.
For engineers and R&D teams: Explore technical research notes on edge latency, visual SLAM and unlabeled data →
FEATURED ARTICLES